WAT
Active Role — Jan 2026 – Present

WATonomous

My Role
Robotics Engineer
Subteam
Autonomy Software
Stack
C++ · ROS2 · STM32 · CAN Bus
Visit the Project Documentation ↗
// 01 — About the Project

The WATonomous Humanoid team is building UWaterloo's first humanoid robot — a dual-arm platform combining mechanical design, electrical systems, and advanced software. The project spans the full engineering stack, from firmware and hardware interfacing to motion control and machine learning.

// Things I've personally worked on

// 02 — Gallery
Compressed 15DOF hand to 7DOF using Geometric Fabrics and PCA in IsaacSim
Description
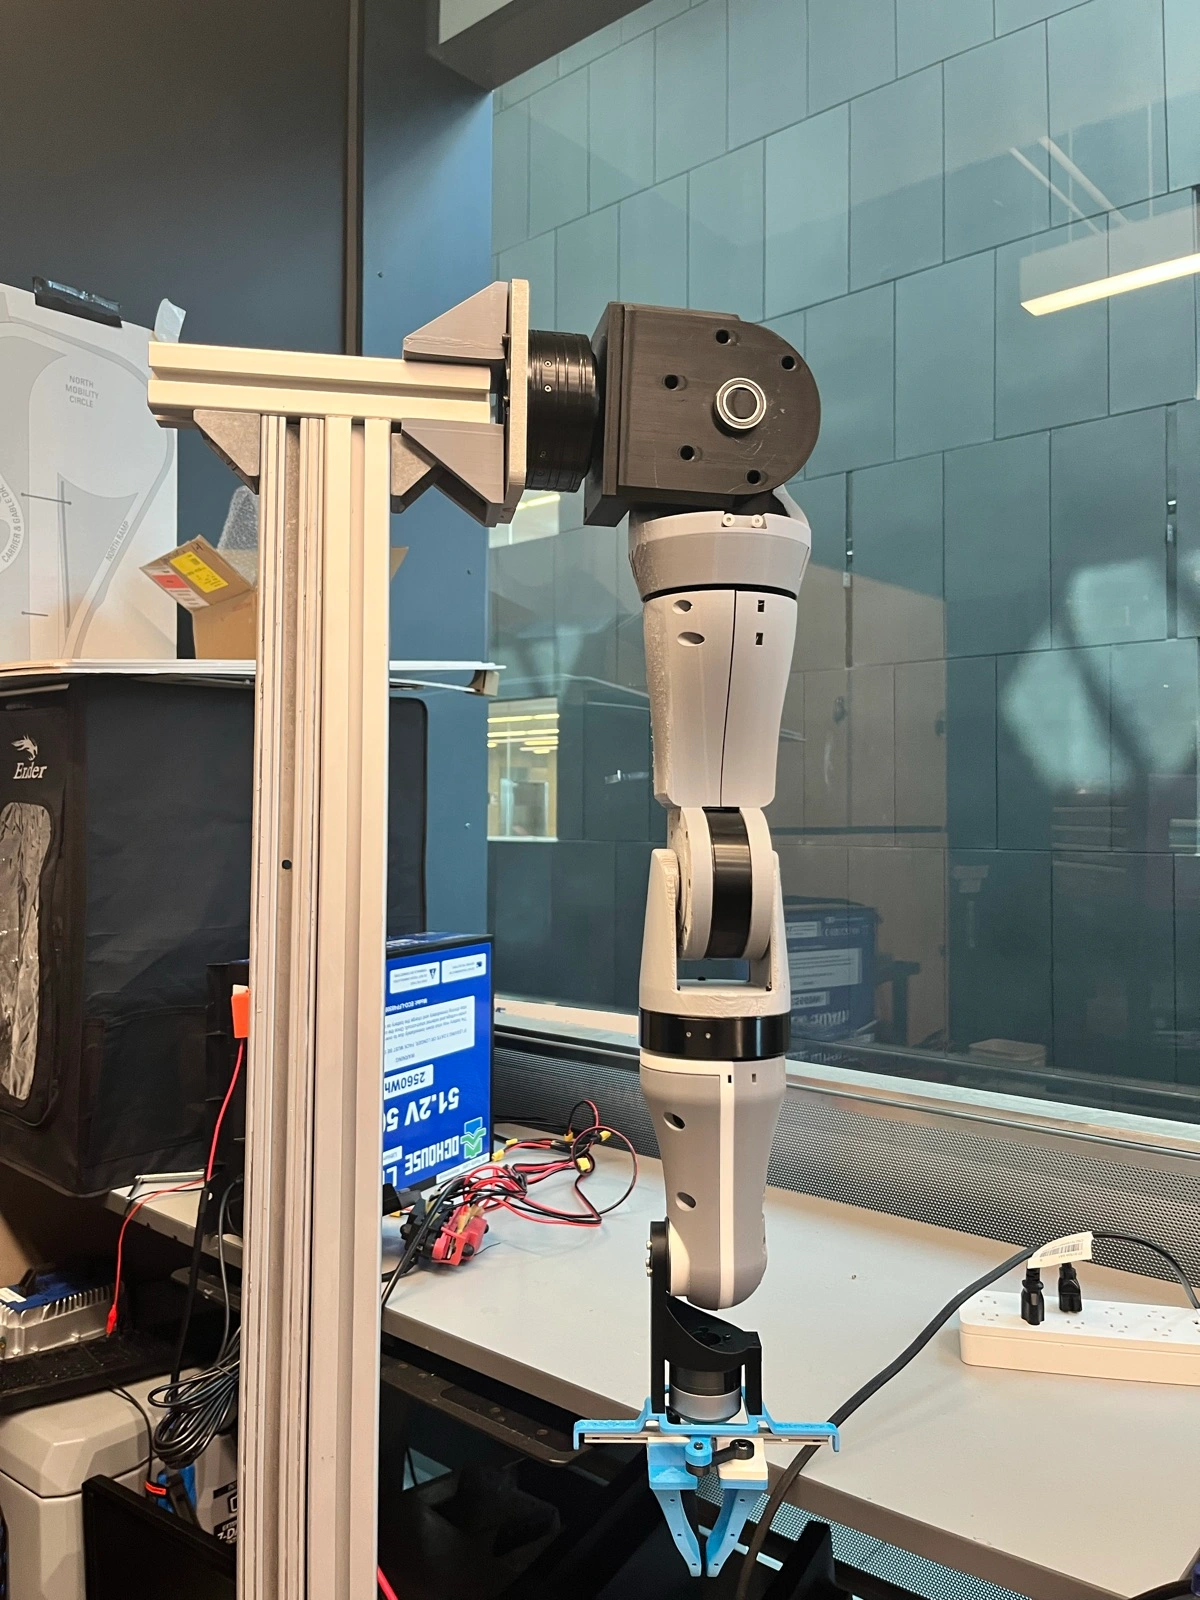
Full 7DOF Arm Redsigned with Solidworks and 3D printed
Description
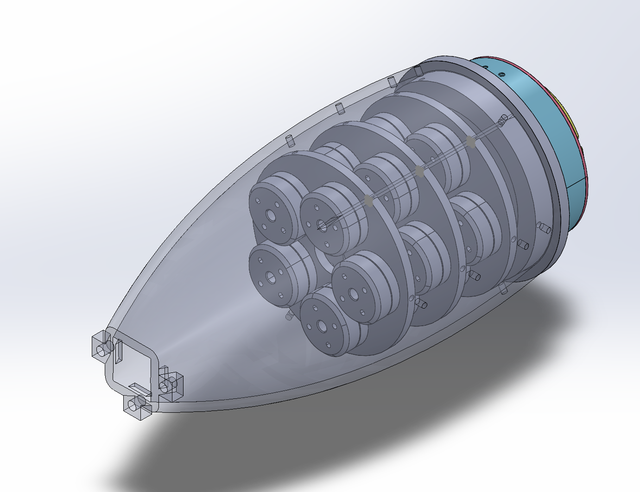
Full anthropomorphic tendon-driven forearm designed in Solidworks
6DOF arm controls setup with CAN and ROS2
01 / 01